School of Mechanical Engineering, Sharif University of Technology
10.22034/jmstsd.2026.606203.1019
Abstract
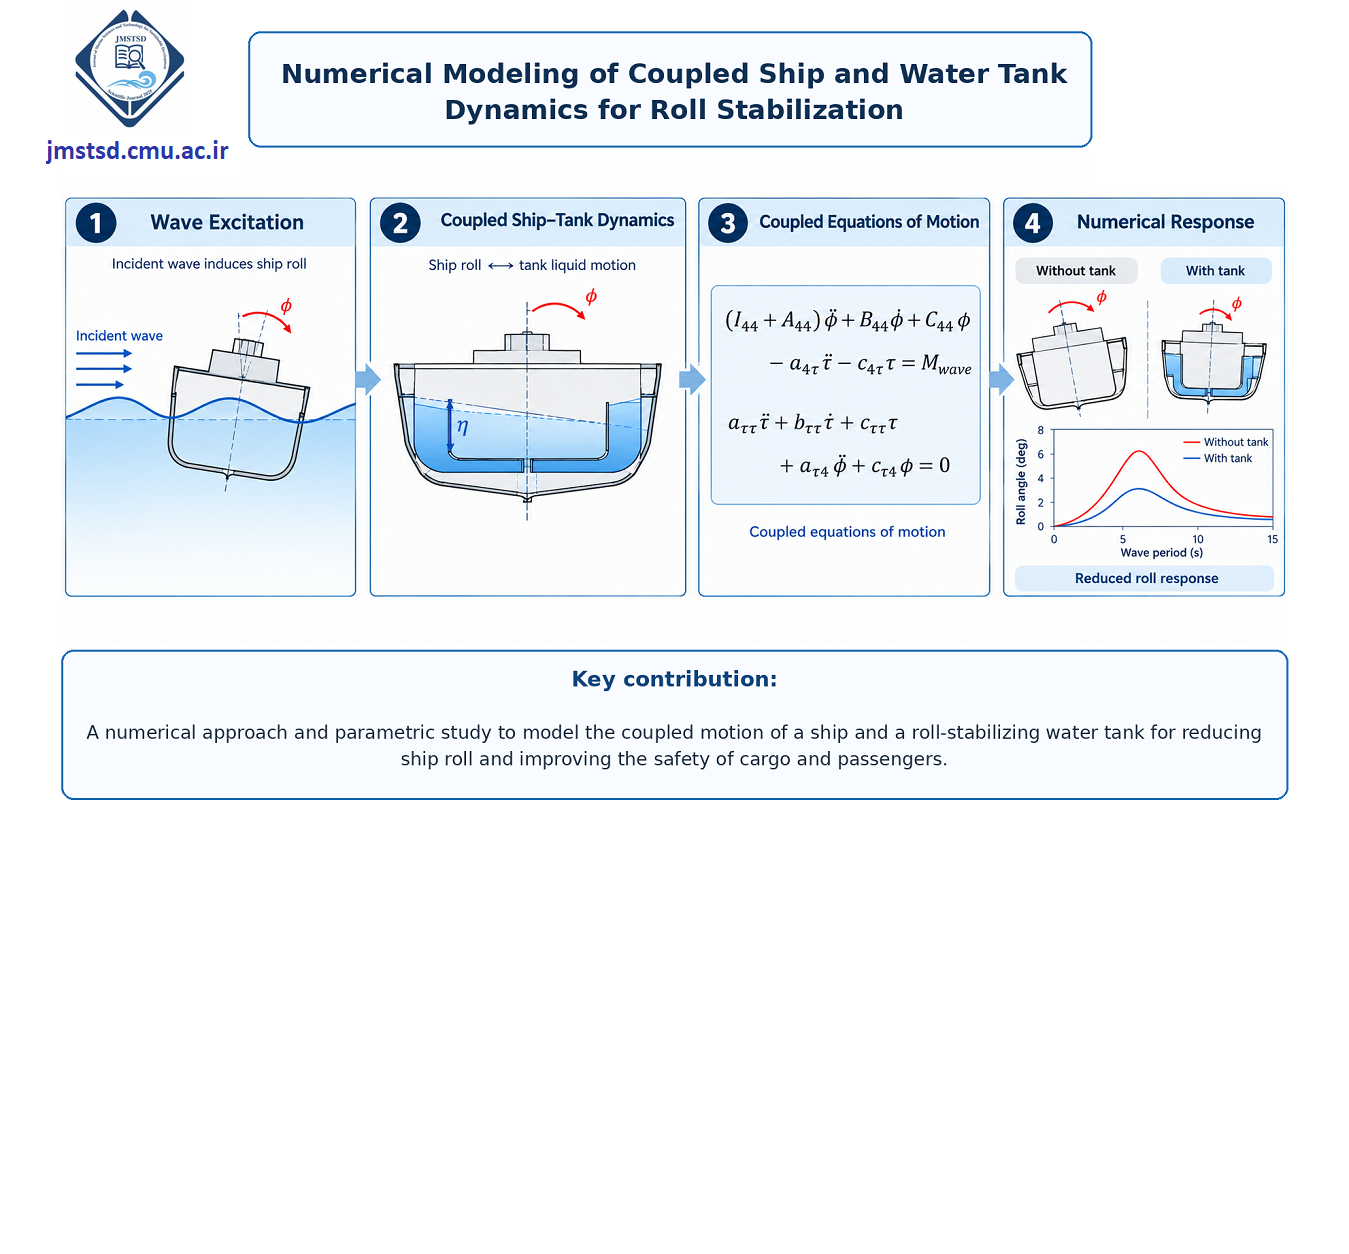
Ship roll motion can adversely affect vessel safety and operational performance, potentially threatening passengers, crew, and cargo. Effective roll stabilization is therefore important for marine transportation. Passive anti-roll water tanks reduce ship roll through the interaction between ship motion and the lateral movement of water inside the tank. This study presents a numerical investigation of ship roll stabilization using a coupled mathematical model of a ship equipped with a passive U-tube anti-roll water tank. Ship roll and tank water motion are formulated as a two-degree-of-freedom system and solved directly in MATLAB using the ODE45 solver. The time-domain responses of two passenger ships are investigated under regular wave excitation to evaluate the influence of the tank on ship roll motion. The results show that the interaction between ship roll and tank water motion can produce an out-of-phase response, leading to reduced roll amplitudes, particularly near the peak-response region. In addition to the time-domain analysis, a frequency-domain formulation based on Goodrich's approach is employed to investigate the dynamic behaviour of the coupled system. A parametric study examines the effects of tank damping, tank natural frequency, coupling strength, and ship damping on the amplification factor and phase angle. Together, these analyses clarify ship–tank interaction and show how key parameters influence system response and stabilization performance. Overall, the study provides a numerical framework for evaluating passive anti-roll water tanks under regular wave conditions and supports the development of roll stabilization systems to improve passenger and crew safety and protect cargo across various operating conditions.
Aziminia, M. (2026). Numerical Modeling of Coupled Ship and Water Tank Dynamics for Roll Stabilization. (e256536). Journal of Marine Sciences and Technology for Sustainable Development, (), e256536 https://doi.org/10.22034/jmstsd.2026.606203.1019
MLA
Aziminia, M. "Numerical Modeling of Coupled Ship and Water Tank Dynamics for Roll Stabilization" .e256536 , Journal of Marine Sciences and Technology for Sustainable Development, , 2026, e256536. doi: 10.22034/jmstsd.2026.606203.1019
HARVARD
Aziminia, M. (2026). 'Numerical Modeling of Coupled Ship and Water Tank Dynamics for Roll Stabilization', Journal of Marine Sciences and Technology for Sustainable Development, (), e256536. doi: 10.22034/jmstsd.2026.606203.1019
CHICAGO
Aziminia, M., "Numerical Modeling of Coupled Ship and Water Tank Dynamics for Roll Stabilization." Journal of Marine Sciences and Technology for Sustainable Development, (2026): e256536, doi: 10.22034/jmstsd.2026.606203.1019
VANCOUVER
Aziminia M. Numerical Modeling of Coupled Ship and Water Tank Dynamics for Roll Stabilization. JMSTSD. 2026;():e256536. doi: 10.22034/jmstsd.2026.606203.1019